EOD Robot with Integrated Manipulator
Tracked remotely controlled platform with an integrated six-axis collaborative arm for EOD training, scene inspection and the handling or transfer of suspicious objects. Supports l
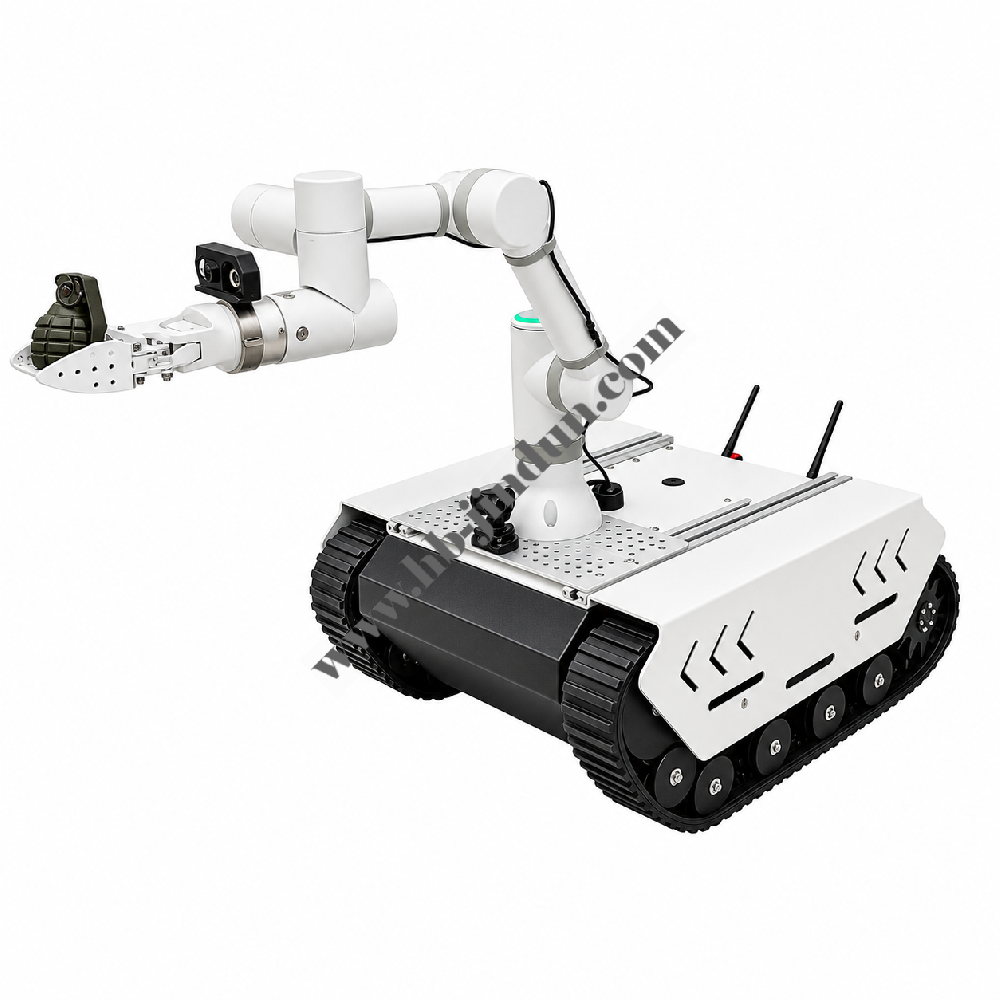
Tracked remotely controlled platform with an integrated six-axis collaborative arm for EOD training, scene inspection and the handling or transfer of suspicious objects. Supports live video transmission, remote operation and custom development.
Technical Specifications
Technical Specifications
1. Platform Specifications
Chassis: rubber-tracked chassis.
Overall dimensions: 950 mm (L) × 620 mm (W) × 580 mm (H), with the arm stowed.
Total weight: ≤115 kg.
Maximum travel speed: 0–1.8 m/s, continuously variable.
Climbing capability: slopes ≤35°.
Obstacle clearance height: ≥120 mm.
Wading capability: shallow-water operation, maximum depth 80 mm.
Steering: differential steering and turning on the spot.
Endurance: ≥4 h under standard operating conditions; quick-change lithium battery pack.
Communications: wireless data and HD video transmission; effective remote-control range ≥1200 m in open areas.
Ingress protection: IP54 for the chassis body.
2. Manipulator Specifications
Manipulator: six-degree-of-freedom collaborative arm.
Maximum arm reach: 1100 mm.
Rated payload: 5 kg at the end effector.
Positioning repeatability: ±0.1 mm.
Gripper: adaptive electric gripper with a 0–180 mm opening, suitable for irregular objects and explosive-device containers.
Joint limits: software and hardware limits, with collision sensing and overload protection.
Operating modes: point control, hand-guided teaching and trajectory playback.
3. Vision and Video Transmission
Main camera: 1080P HD low-light camera with infrared illumination for dim environments.
Auxiliary view: chassis side camera for observing tracks and ground obstacles.
Video transmission: low-latency wireless HD video, latency